
DISCUSSIONSTARTED BY WBH
Sim-to-real: what made your policy fail on the real robot?
Development & softwareUnitree G1WBH Editorial ·
Unitree RoboticsHumanoid robotAnnounced
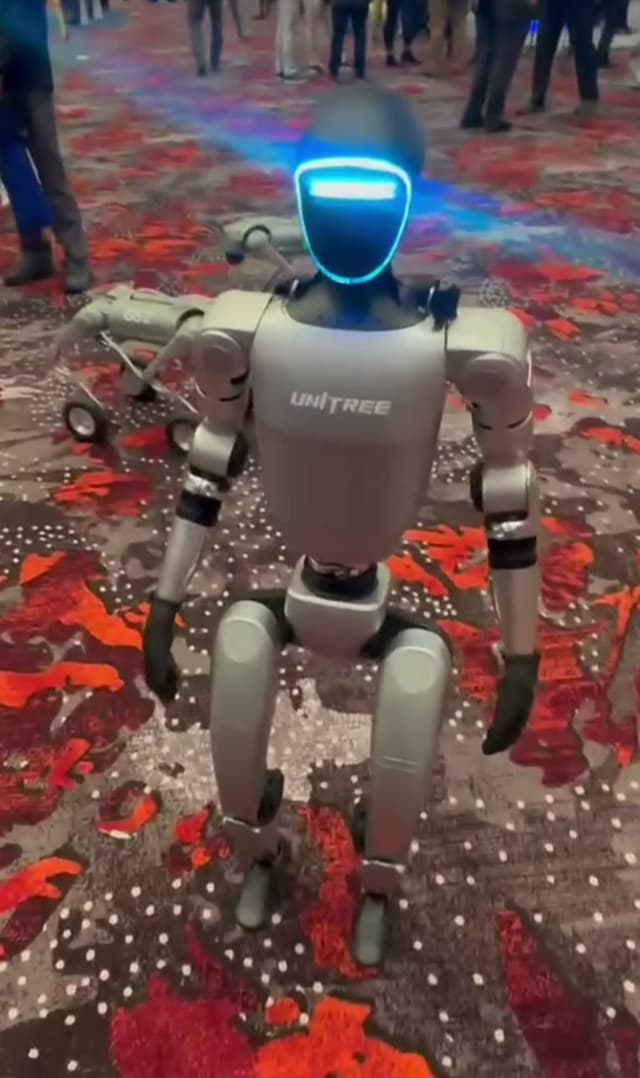
Unitree G1 is a humanoid robot from Unitree Robotics, introduced on 13 May 2024. It stands 1.32 m tall, weighs about 35 kg with its battery and has 23 joint degrees of freedom; the G1 EDU variant adds optional waist, wrist and Dex3-1 hand joints for up to 43. Unitree publishes a C++ and Python SDK, ROS 2 packages, URDF and MJCF models, and reinforcement-learning environments for Isaac Lab and MuJoCo. Secondary development is listed for G1 EDU only.
EDITORIALOverview reviewed against the cited sources by WBH, .
DATA · 37 FIELDS
| Height | 1.32 mStanding; width 450 mm, thickness 200 mm | Official source [1] |
|---|---|---|
| Folded dimensions | 690 × 450 × 300 mmHeight × width × thickness | Official source [1] |
| Weight | ~35 kgWith battery; G1 EDU is listed as “about 35 kg+” | Official source [1] |
| Degrees of freedom | 23–4323 on G1; 23–43 on G1 EDU with optional waist, wrist and hand joints | Official source [1] |
| Leg DOF | 6 per leg | Official source [1] |
| Waist DOF | 1G1 EDU: 2 additional waist DOF optional | Official source [1] |
| Arm DOF | 5 per arm | Official source [1] |
| Calf + thigh length | 0.6 m | Official source [1] |
| Arm span | ~0.45 mAs listed by Unitree | Official source [1] |
| Locomotion | BipedalTwo legs, 6 DOF each | Official source [1] |
| Walking speed | Not published | Not published |
| Ingress protection | Not published | Not published |
| Joint motors | Low-inertia internal-rotor PMSMPermanent magnet synchronous motors | Official source [1] |
|---|---|---|
| Joint output bearings | Crossed roller bearingsIndustrial grade | Official source [1] |
| Joint encoders | Dual encoder | Official source [1] |
| Max knee torque |
| Official source [1] |
| Knee range | 0–165° | Official source [1] |
| Hip range | P ±154° · R −30° to +170° · Y ±158° | Official source [1] |
| Waist range | Z ±155°G1 EDU adds X ±30° and Y ±30° | Official source [1] |
| Wrist range |
| Official source [1] |
| Electrical routing | Hollow through all joints | Official source [1] |
| Cooling | Local air cooling | Official source [1] |
| Battery | 13-string lithium, 9,000 mAhQuick-release smart battery | Official source [1] |
|---|---|---|
| Battery life | ~2 h | Official source [1] |
| Charger | 54 V, 5 A | Official source [1] |
| Charging time | Not published | Not published |
| Compute | 8-core CPUG1 EDU: optional high-computing-power module; Unitree names Orin as an example | Official source [1] |
|---|---|---|
| Perception sensors | Depth camera + 3D LiDAR | Official source [1] |
| Audio | 4-microphone array, 5 W speaker | Official source [1] |
| Connectivity | Wi-Fi 6, Bluetooth 5.2 | Official source [1] |
| OTA software updates | Yes | Official source [1] |
| End effector | Optional Dex3-1 three-finger hand (G1 EDU)7 active DOF per hand (thumb 3, index 2, middle 2), optional tactile sensor arrays, +2 optional wrist DOF. No hand is listed for G1. | Official source [1] |
|---|---|---|
| Arm payload |
| Official source [1] |
| Indicative price | From US$13,500G1, excluding tax and shipping; G1 EDU price on request | Official source [1] |
|---|---|---|
| Availability | Available to orderListed with a price; independent teams used G1 hardware in 2025 competitions | Official source [1][2] |
| Secondary development | G1 EDU onlyThe parameter table lists secondary development for G1 EDU, not for G1 | Official source [1] |
| Warranty |
| Official source [1] |
DATA · SOFTWARE & SIMULATION
| INTERFACE | SUPPORT | PACKAGE / VERSION | SRC |
|---|---|---|---|
| SDK | Official | unitree_sdk2 2.0.2 (C++) · G1 examples · G1 EDU | [1][3][4] |
| ROS 2 | Official | unitree_ros2 · Foxy, Humble | [6] |
| Isaac Sim / Lab | Official | unitree_rl_lab (Isaac Lab 2.3.0) · unitree_rl_gym (Isaac Gym) | [9][10] |
| MuJoCo | Official | unitree_mujoco · MuJoCo Menagerie model | [8][9][11] |
| Gazebo | Not published | No official G1 Gazebo launch files | [7] |
| URDF / MJCF | Official | unitree_ros · g1_description (23- and 29-DOF models) | [7] |
| Languages | Official | C++, Python | [3][5] |
IN SHORT
DATA · 19 COMPARISONS
7 SPECIFICATIONS
AGIBOT A2 (A2 Ultra / A2 Lite) vs Unitree G1AGIBOT A2 (A2 Ultra / A2 and G1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT A3 Ultra vs Unitree G1AGIBOT A3 Ultra and G1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
4 SPECIFICATIONS
AGIBOT A3 vs Unitree G1AGIBOT A3 and G1 compared: height, weight, runtime, battery and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT X2 vs Unitree G1X2 and G1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
5 SPECIFICATIONS
Agility Digit 5 vs Unitree G1Digit 5 and G1 compared: height, weight, runtime, battery and more, as their makers publish them.
6 SPECIFICATIONS
Booster T1 vs Unitree G1T1 and G1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
5 SPECIFICATIONS
EngineAI T800 vs Unitree G1EngineAI T800 and G1 compared: height, weight, degrees of freedom, battery life and more, as their makers publish them.
4 SPECIFICATIONS
Figure 03 vs Unitree G1Figure 03 and G1 compared: height, weight, runtime, battery and more, as their makers publish them.
7 SPECIFICATIONS
LimX Luna vs Unitree G1LimX Luna and G1 compared: height, weight, active dof, runtime and more, as their makers publish them.
7 SPECIFICATIONS
LimX Oli vs Unitree G1LimX Oli and G1 compared: height, weight, active dof, runtime and more, as their makers publish them.
7 SPECIFICATIONS
NEO vs Unitree G1NEO and G1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
7 SPECIFICATIONS
PAL Robotics KANGAROO vs Unitree G1KANGAROO and G1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
7 SPECIFICATIONS
PAL Robotics TALOS vs Unitree G1TALOS and G1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
6 SPECIFICATIONS
ROBOTERA L7 vs Unitree G1ROBOTERA L7 and G1 compared: height, weight, degrees of freedom, arm payload and more, as their makers publish them.
6 SPECIFICATIONS
Unitree G1 vs Unitree G1-CompG1 and Unitree G1-Comp compared: height, weight, degrees of freedom, battery life and more, as their makers publish them.
5 SPECIFICATIONS
Unitree G1 vs Unitree G1-DG1 and Unitree G1-D compared: weight, degrees of freedom, battery life, arm payload and more, as their makers publish them.
6 SPECIFICATIONS
Unitree G1 vs Unitree H1G1 and H1 compared: height, weight, degrees of freedom, arm payload and more, as their makers publish them.
7 SPECIFICATIONS
Unitree G1 vs Unitree H2G1 and H2 compared: height, weight, degrees of freedom, battery life and more, as their makers publish them.
7 SPECIFICATIONS
Unitree G1 vs Unitree R1G1 and R1 compared: height, weight, degrees of freedom, battery life and more, as their makers publish them.
DATA · 6 ROBOTS
Compare the Unitree G1 with the closest three side by side
See also commercially available humanoid robots.
TIMELINE · 25 EVENTS SINCE 13 MAY 2024
COMMUNITY · 5 THREADS
Development & softwareUnitree G1WBH Editorial ·
Development & softwareUnitree G1WBH Editorial ·
Hardware & ownershipUnitree G1Unitree H2WBH Editorial ·
Hardware & ownershipUnitree G1Unitree H2WBH Editorial ·
Hardware & ownershipUnitree G1VegaWBH Editorial ·
Community posts are written by members and are not checked by WBH. Facts on robot pages come from cited sources; report a data error to have it corrected.