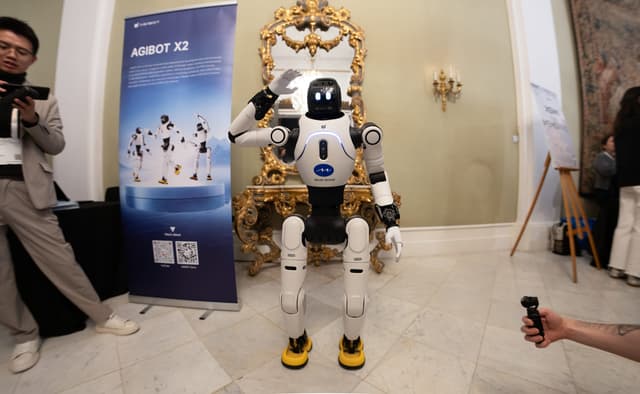

AGIBOT X2
AGIBOTHumanoid robot
AGIBOT X2 is a humanoid robot line sold by AGIBOT (Shanghai) through its online store as the AGIBOT X2 Neo and the AGIBOT X2 Ultra (New Version), with an X2 EDU education variant and an older X2 Ultra hardware revision documented in AGIBOT's AimDK_X2 developer docs. The current flagship, X2 Ultra (New Version), is about 1.31 m tall, weighs about 39 kg and has 31 degrees of freedom, including 2 in the neck, 7 per arm, 3 in the waist and 6 per leg. It carries a LiDAR, an RGB-D camera, stereo and monocular RGB cameras and a head touch sensor, driven by an RK3588s+RK3588 motion-control computer and an NVIDIA Jetson Orin NX (157 TOPS) development computer. AGIBOT documents an AimDK_X2 secondary-development SDK built on ROS 2 with Python and C++ interfaces, a MuJoCo-based simulation environment, a reinforcement-learning deployment pipeline using ONNX Runtime, and open-source URDF/MJCF models on GitHub. Secondary development is documented for the Ultra-tier hardware (X2 Ultra, X2 Ultra (New Version), X2 EDU) but the main product page marks it 'Not supported' for the plain X2 unit.
EDITORIALOverview reviewed against the cited sources by WBH, .
- HEIGHT
- ≈1.31 m
- WEIGHT
- ≈39 kg · ≈33 kg (X2 EDU) · ≈35 kg (X2 Neo)
- DOF
- 31
- RUNTIME
- ≈2 h
DATA · 24 FIELDS
Specifications
- Official source
- Community measured
- Not published
| Height | ≈1.31 mX2 Ultra (New Version); identical dimensions given for X2 Ultra and X2 EDU. | Official source [6][9] |
|---|---|---|
| Weight |
| Official source [5][6][9] |
| Degrees of freedom |
| Official source [5][6][9] |
| Locomotion | Bipedal | Official source [3] |
| Walking speed | Up to 1.8 m/s (typical ≤0.8 m/s)Same figures published for X2 and X2 Ultra. | Official source [3][9] |
| Ingress protection | Not published | Not published |
| Peak joint torque | 120 N·mPublished as an overall peak figure; the specific joint is not named. Same value for X2, X2 Ultra, X2 Ultra(new version) and X2 EDU. | Official source [3][9] |
|---|---|---|
| Arm DOF (per arm) | 7 per armConsistent across X2 Ultra, X2 Ultra(new version), X2 EDU and X2 Neo. The main product page's older 'X2' SKU instead lists 5 DOF per arm (see discrepancies). | Official source [4][5][9] |
| Leg DOF (per leg) | 6 per legConsistent across X2 Ultra, X2 Ultra(new version) and X2 EDU. | Official source [9] |
| Waist DOF | 3Consistent across X2 Ultra, X2 Ultra(new version) and X2 EDU (yaw, pitch, roll per the main product page). | Official source [9] |
| Neck DOF |
| Official source [5][6][9] |
| Battery capacity | ≈421 WhAimDK_X2 developer docs figure, same for X2 Ultra, X2 Ultra(new version) and X2 EDU. The main product page instead states approx. 500 Wh (see discrepancies). | Official source [9] |
|---|---|---|
| Runtime | ≈2 hAt a continuous 0.5 m/s walking pace, not a general idle/standby runtime. | Official source [3][9] |
| Charging time | ≤1.5 h | Official source [9] |
| Compute | RK3588s+RK3588 + Jetson Orin NX (157 TOPS) | Official source [9][10] |
|---|---|---|
| Perception sensors | LiDAR, RGB-D, stereo/mono RGB, touch, IMU, GNSS (Ultra-tier only) | Official source [11] |
| Connectivity | Wi-Fi, Bluetooth, 4G/5G (+UWB on New Version) | Official source [9] |
| Arm reach (per arm, excl. end-effector) | 558 mmSame figure published for X2 Ultra, X2 Ultra(new version) and X2 EDU. | Official source [9] |
|---|---|---|
| End-effector | Optional OmniHand / OmniPicker | Official source [3][8] |
| Payload | 3 kg max / ≤1 kg full-rangeNot arm-specific; same figures for X2 Ultra, X2 Ultra(new version) and X2 EDU. | Official source [9] |
| Hand DOF | Not publishedOmniHand is documented as an optional module, but no DOF count for it is stated on the retrieved pages. | Not published |
| Indicative price |
| Official source [5] |
|---|---|---|
| Availability | Orderable online (Neo) / contact sales (Ultra) | Official source [5][6] |
| Warranty | Not publishedAn 'AGIBOT X2 After-sales Service Guide' is listed in the Document Center navigation, but its content page was not retrieved/read. | Not published |
DATA · SOFTWARE & SIMULATION
AGIBOT X2 SDK, ROS 2, URDF and simulation
| INTERFACE | SUPPORT | PACKAGE / VERSION | SRC |
|---|---|---|---|
| SDK | Official | AimDK_X2: a task-level secondary-development framework with Python and C++ APIs, plus example code, an interface reference and a downloadable SDK package. Full secondary development is documented for X2 Ultra and X2 Ultra(new version); X2 EDU supports motion-control-only secondary development; the base 'X2' entry on the main product page is marked 'Not supported'. | [3][7][9] |
| ROS 2 | Official | AimDK_X2 is built on ROS 2 (Humble); ships a custom aimdk_msgs message package plus 'py_examples' and 'x2_rl_deploy_controller' ROS 2 nodes/topics for joint state, IMU and motion commands. | [7][13][14] |
| Isaac Sim / Lab | Not published | No Isaac Sim/Lab tutorial, importer or environment is documented for X2. The agibot_x2_urdf GitHub repository carries an 'issacsim' topic tag, but no Isaac-specific content, model or guide was found. | [16] |
| MuJoCo | Official | Official MJCF models (scene.xml, x2_ultra.xml / X2-Ultra.xml / X2-EDU.xml, plus omnihand/omnipicker variants) in the agibot_x2_urdf repository, and an official 'X2 MuJoCo Motion-Control Simulation' guide with local (ROS 2 Humble) or Docker deployment on Ubuntu 22.04. | [13][17] |
| Gazebo | Not published | No Gazebo model or integration is documented for X2. | |
| URDF / MJCF | Official | URDF and MJCF models for X2 Ultra (v1.3.0), X2 Ultra(new version) and X2 EDU (v1.4.0), including OmniHand/OmniPicker end-effector variants, open-sourced on GitHub (AgibotTech/agibot_x2_urdf) under the Mulan PSL v2 license. | [12][17] |
| Languages | Official | Python and C++ APIs, with example code for both in the AimDK_X2 documentation. | [7] |
| Teleoperation | Official | Handheld remote controller included as standard on X2 Ultra, X2 Ultra(new version) and X2 EDU; optional teleoperation accessories for X2 Ultra; AimDK docs cover remote-controller connection and PS5-gamepad control (ROS 2 'joy' node) during RL-policy testing. | [8][9][14] |
| Reinforcement learning deployment | Official | Official 'X2 RL Deploy' package: an ONNX-policy motion-control ROS 2 node (x2_rl_deploy_controller) paired with a MuJoCo simulation node and a joystick node; policies are trained externally and deployed via ONNX Runtime v1.23.2. | [14] |
IN SHORT
AGIBOT X2: quick answers
- How tall is the AGIBOT X2?
- ≈1.31 m, as AGIBOT publishes it.
- How much does the AGIBOT X2 weigh?
- ≈39 kg, as AGIBOT publishes it.
- How many degrees of freedom does the AGIBOT X2 have?
- 29–31, according to AGIBOT.
- Does the AGIBOT X2 have an SDK?
- Yes: AGIBOT publishes AimDK_X2: a task-level secondary-development framework with Python and C++ APIs, plus example code, an interface reference and a downloadable SDK package. Full secondary development is documented for X2 Ultra and X2 Ultra(new version); X2 EDU supports motion-control-only secondary development; the base 'X2' entry on the main product page is marked 'Not supported'..
- Does the AGIBOT X2 support ROS 2?
- Yes: AGIBOT publishes AimDK_X2 is built on ROS 2 (Humble); ships a custom aimdk_msgs message package plus 'py_examples' and 'x2_rl_deploy_controller' ROS 2 nodes/topics for joint state, IMU and motion commands..
HARDWARE · AFFILIATE LINKS
Hardware named on this page
- NVIDIA Jetson Orin NX Module 16GB at Seeed StudioNamed in AGIBOT X2's specifications (Compute): Jetson Orin NX
Listed because this page names the model; being named is not evidence that a product is compatible with, or identical to, what a robot uses. Affiliate links: if you buy through one, Seeed Studio may pay WBH a commission, at no extra cost to you. It plays no part in what WBH covers or names. How recommendations are chosen.
DATA · 21 COMPARISONS
Compare AGIBOT X2
7 SPECIFICATIONS
AGIBOT A2 (A2 Ultra / A2 Lite) vs AGIBOT X2AGIBOT A2 (A2 Ultra / A2 and X2 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
5 SPECIFICATIONS
AGIBOT A3 Ultra vs AGIBOT X2AGIBOT A3 Ultra and X2 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
4 SPECIFICATIONS
AGIBOT A3 vs AGIBOT X2AGIBOT A3 and X2 compared: height, weight, runtime, battery and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT X2 vs Agility Digit 5X2 and Digit 5 compared: height, weight, runtime, payload and more, as their makers publish them.
7 SPECIFICATIONS
AGIBOT X2 vs Booster T1X2 and T1 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
7 SPECIFICATIONS
AGIBOT X2 vs Boston Dynamics AtlasX2 and Atlas compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT X2 vs EngineAI T800X2 and EngineAI T800 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT X2 vs Figure 03X2 and Figure 03 compared: height, weight, walking speed, runtime and more, as their makers publish them.
7 SPECIFICATIONS
AGIBOT X2 vs Fourier GR-3X2 and GR-3 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
7 SPECIFICATIONS
AGIBOT X2 vs HMND 01 Alpha BipedalX2 and HMND 01 Alpha Bipedal compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
7 SPECIFICATIONS
AGIBOT X2 vs LimX LunaX2 and LimX Luna compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
7 SPECIFICATIONS
AGIBOT X2 vs LimX OliX2 and LimX Oli compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
7 SPECIFICATIONS
AGIBOT X2 vs PAL Robotics KANGAROOX2 and KANGAROO compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT X2 vs PAL Robotics TALOSX2 and TALOS compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
5 SPECIFICATIONS
AGIBOT X2 vs ROBOTERA L7X2 and ROBOTERA L7 compared: height, weight, degrees of freedom, battery capacity and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT X2 vs Unitree G1X2 and G1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT X2 vs Unitree G1-CompX2 and Unitree G1-Comp compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT X2 vs Unitree H1X2 and H1 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT X2 vs Unitree H2X2 and H2 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
6 SPECIFICATIONS
AGIBOT X2 vs Unitree R1X2 and R1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
8 SPECIFICATIONS
NEO vs AGIBOT X2NEO and X2 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
DATA · 6 ROBOTS
Robots similar to the AGIBOT X2
- Unitree G1Unitree1.32 m · ~35 kg · 23–43 DoF
- Unitree G1-CompUnitreeabout 1.3 m · about 35 kg · 25 DoF
- Unitree R1Unitree1.23 m · ≈27–29 kg · 20–40 DoF
- Booster T1Booster1.18 m · ~30 kg · 23 DoF
- LimX LunaLimX Dynamics1.6 m · 56 kg · 27 DoF
- PAL Robotics KANGAROOPAL1.6 m · 50–65 kg · 14–40 DoF
Compare the AGIBOT X2 with the closest three side by side
See also commercially available humanoid robots.
TIMELINE · 8 EVENTS
Latest updates
- AGIBOT Opens Hong Kong Office in Causeway Bay
- AGIBOT Partners with Vietnam National Innovation Center(NIC) to Advance Embodied AI Industry and Talent Ecosystem
- IDC Data Shows AGIBOT Led Global Humanoid Robot Shipments in H1 2026
- AGIBOT and ASD Deploy 100 AGIBOT X2 Humanoid Robots Across 100 Retail Stores
- AGIBOT Demonstrates WITA
- AGIBOT Releases GE
- AGIBOT launches AGILE 2.0 perception-driven locomotion framework, demoed on X2
- AGIBOT security advisory SA-2026-0001: unauthenticated MQTT on X2 Ultra v0.9.7, fixed in v1.0.0
COMMUNITY · 0 THREADS
Discussions about AGIBOT X2
No community threads about AGIBOT X2 yet. Own one, develop for one or evaluating it? Ask a question or share what you learned: it will appear here.
Community posts are written by members and are not checked by WBH. Facts on robot pages come from cited sources; report a data error to have it corrected.