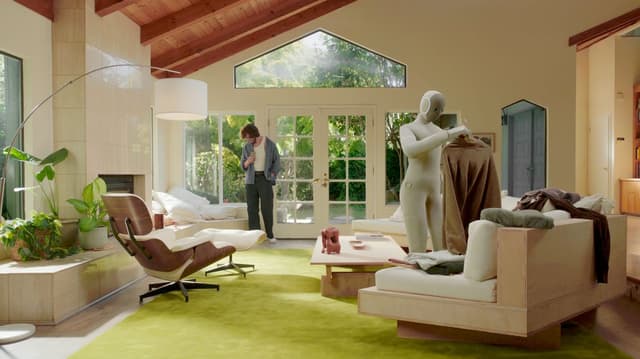
NEO
1X TechnologiesFull-size humanoid robot
NEO is a full-size humanoid robot made by 1X Technologies. This record lists what 1X Technologies publishes about it, each value with its source; anything the manufacturer does not publish is marked "Not published".
EDITORIALOverview reviewed against the cited sources by WBH, .
DATA · 25 FIELDS
Specifications
- Official source
- Community measured
- Not published
| Height | 5’6” (as published; approx. 1.68 m) | Official source [3] |
|---|---|---|
| Weight | 66 lb (as published; approx. 30 kg) | Official source [3] |
| Degrees of freedom | Hands 22x2, Arms 7x2, Neck 3, Spine 2, Legs 6x2 (as listed; 1X does not state a total) | Official source [3] |
| Walking speed | 1.4 m/s | Official source [3] |
| Running speed | 6.2 m/s max run speed | Official source [3] |
| Ingress protection | Hands IP68, body IP44 | Official source [3] |
| Operating temperature | Not published | Not published |
| Locomotion | Not published | Not published |
| Hand DoF | 22 per hand (spec sheet); 1X's hand post says 25 DoF = 22 fingers/palm + 3 wrist | Official source [3][4] |
|---|---|---|
| Actuators | 1X Tendon Drive: low-inertia tendon drives (1X claims 2% torque accuracy, 95% backdrivability) | Official source [3] |
| Max joint torque | Not published | Not published |
| Battery | 842 Wh | Official source [3] |
|---|---|---|
| Runtime | 4 h | Official source [3] |
| Charging time | Quick charge: 6 min per hour of runtime; self-docking | Official source [3] |
| Battery swap | Not published | Not published |
| Cameras | Dual 8.85 MP 90 Hz stereo fisheye | Official source [3] |
|---|---|---|
| Perception sensors | Stereo fisheye cameras, 4 beamforming microphones, link-wise IMUs, joint force sensing | Official source [3] |
| Compute | 1X NEO Cortex (NVIDIA Jetson Thor), up to 2070 FP4 TFLOPS | Official source [3] |
| Connectivity | Wi-Fi, Bluetooth, 5G | Official source [3] |
| LiDAR | Not published | Not published |
| Arm payload | 18 lb (as published) | Official source [3] |
|---|---|---|
| Payload | Lift 154 lb; carry 55 lb (as published) | Official source [3] |
| End effector | Five-finger tendon-driven hands, force-controlled and backdrivable, with tactile/shear skin (per 1X hands post) | Official source [4] |
| Indicative price | US$20,000 (Early Access ownership) or US$499/month subscription | Official source [5] |
|---|---|---|
| Availability | Pre-order ($200 refundable deposit); US deliveries 'start 2026'; other markets from 2027 | Official source [5][6] |
DATA · SOFTWARE & SIMULATION
Development
| INTERFACE | SUPPORT | PACKAGE / VERSION | SRC |
|---|---|---|---|
| SDK | Not published | ||
| Teleoperation | Official | Scheduled 'Expert Mode': a 1X operator remotely supervises NEO for tasks it cannot yet do; owners can also pilot NEO via the mobile app and a VR device. | [3] |
| Reinforcement learning tooling | Not published | ||
| ROS 2 | Not published | ||
| NVIDIA Isaac Sim / Isaac Lab | Not published | ||
| MuJoCo | Not published | ||
| Gazebo | Not published | ||
| Robot description (URDF/MJCF) | Not published | ||
| Programming languages | Not published |
IN SHORT
NEO: quick answers
- How tall is the 1X NEO?
- 5’6” (as published; approx. 1.68 m), as 1X publishes it.
- How much does the 1X NEO weigh?
- ≈29.9 kg, as 1X publishes it.
- How many degrees of freedom does the 1X NEO have?
- Hands 22x2, Arms 7x2, Neck 3, Spine 2, Legs 6x2 (as listed; 1X does not state a total), according to 1X.
HARDWARE · AFFILIATE LINKS
Hardware named on this page
- NVIDIA Jetson AGX Thor Developer Kit Bundle at Seeed StudioNamed in NEO's specifications (Compute): Jetson Thor
Listed because this page names the model; being named is not evidence that a product is compatible with, or identical to, what a robot uses. Affiliate links: if you buy through one, Seeed Studio may pay WBH a commission, at no extra cost to you. It plays no part in what WBH covers or names. How recommendations are chosen.
DATA · 22 COMPARISONS
Compare NEO
4 SPECIFICATIONS
NEO vs 4NE1 Gen 3.5NEO and 4NE1 Gen 3.5 compared: height, weight, walking speed, payload and more, as their makers publish them.
8 SPECIFICATIONS
NEO vs AGIBOT A2 (A2 Ultra / A2 Lite)NEO and AGIBOT A2 (A2 Ultra / A2 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
4 SPECIFICATIONS
NEO vs AGIBOT A3NEO and AGIBOT A3 compared: height, weight, runtime, battery and more, as their makers publish them.
6 SPECIFICATIONS
NEO vs AGIBOT A3 UltraNEO and AGIBOT A3 Ultra compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
8 SPECIFICATIONS
NEO vs AGIBOT X2NEO and X2 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
6 SPECIFICATIONS
NEO vs Agility Digit 5NEO and Digit 5 compared: height, weight, runtime, payload and more, as their makers publish them.
7 SPECIFICATIONS
NEO vs Booster T1NEO and T1 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
8 SPECIFICATIONS
NEO vs Boston Dynamics AtlasNEO and Atlas compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
6 SPECIFICATIONS
NEO vs EngineAI T800NEO and EngineAI T800 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
6 SPECIFICATIONS
NEO vs Figure 03NEO and Figure 03 compared: height, weight, walking speed, runtime and more, as their makers publish them.
8 SPECIFICATIONS
NEO vs Fourier GR-3NEO and GR-3 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
7 SPECIFICATIONS
NEO vs HMND 01 Alpha BipedalNEO and HMND 01 Alpha Bipedal compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
8 SPECIFICATIONS
NEO vs LimX LunaNEO and LimX Luna compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
8 SPECIFICATIONS
NEO vs LimX OliNEO and LimX Oli compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
8 SPECIFICATIONS
NEO vs PAL Robotics KANGAROONEO and KANGAROO compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
7 SPECIFICATIONS
NEO vs PAL Robotics TALOSNEO and TALOS compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
7 SPECIFICATIONS
NEO vs Unitree G1NEO and G1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
6 SPECIFICATIONS
NEO vs Unitree G1-CompNEO and Unitree G1-Comp compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
5 SPECIFICATIONS
NEO vs Unitree G1-DNEO and Unitree G1-D compared: weight, degrees of freedom, runtime, arm payload and more, as their makers publish them.
7 SPECIFICATIONS
NEO vs Unitree H1NEO and H1 compared: height, weight, degrees of freedom, walking speed and more, as their makers publish them.
7 SPECIFICATIONS
NEO vs Unitree H2NEO and H2 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
7 SPECIFICATIONS
NEO vs Unitree R1NEO and R1 compared: height, weight, degrees of freedom, runtime and more, as their makers publish them.
DATA · 6 ROBOTS
Robots similar to the NEO
- 4NE1 Gen 3.5NEURA1.8 m · 80 kg
- AGIBOT A2 (A2 Ultra / A2 Lite)AGIBOT1.69 m · ≈69 kg (Ultra) / ≈64 kg (Lite) · 40 (Ultra) / 23 (Lite) DoF
- AGIBOT A3AGIBOT1.73 m · 55 kg
- AGIBOT A3 UltraAGIBOT1.74 m · 60 kg · 51 active DoF
- AGIBOT X2AGIBOT≈1.31 m · ≈39 kg · 29–31 DoF
- Agility Digit 5Agility1.81 m · 129 kg
TIMELINE · 5 EVENTS
Latest updates
COMMUNITY · 0 THREADS
Discussions about NEO
No community threads about NEO yet. Own one, develop for one or evaluating it? Ask a question or share what you learned: it will appear here.
Community posts are written by members and are not checked by WBH. Facts on robot pages come from cited sources; report a data error to have it corrected.